RapidBase
Autonomy / Robotics / The Future
SYS://LOAD
RapidBase

Comprehensive system
of technologies for autonomization

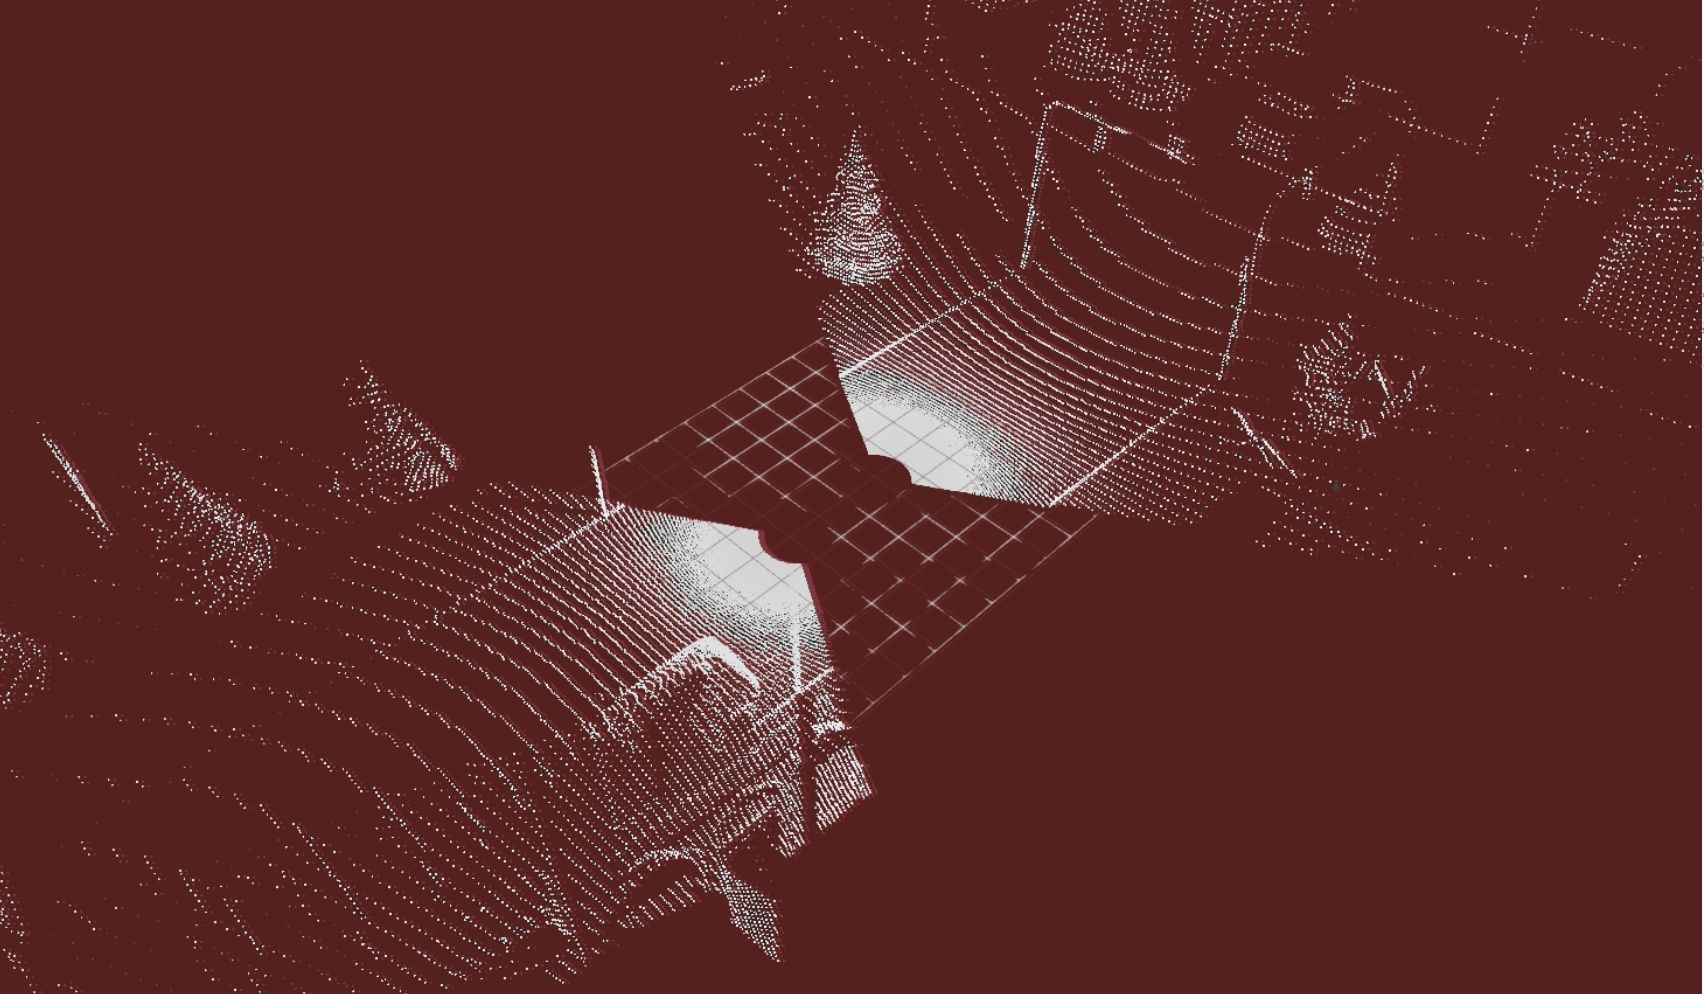
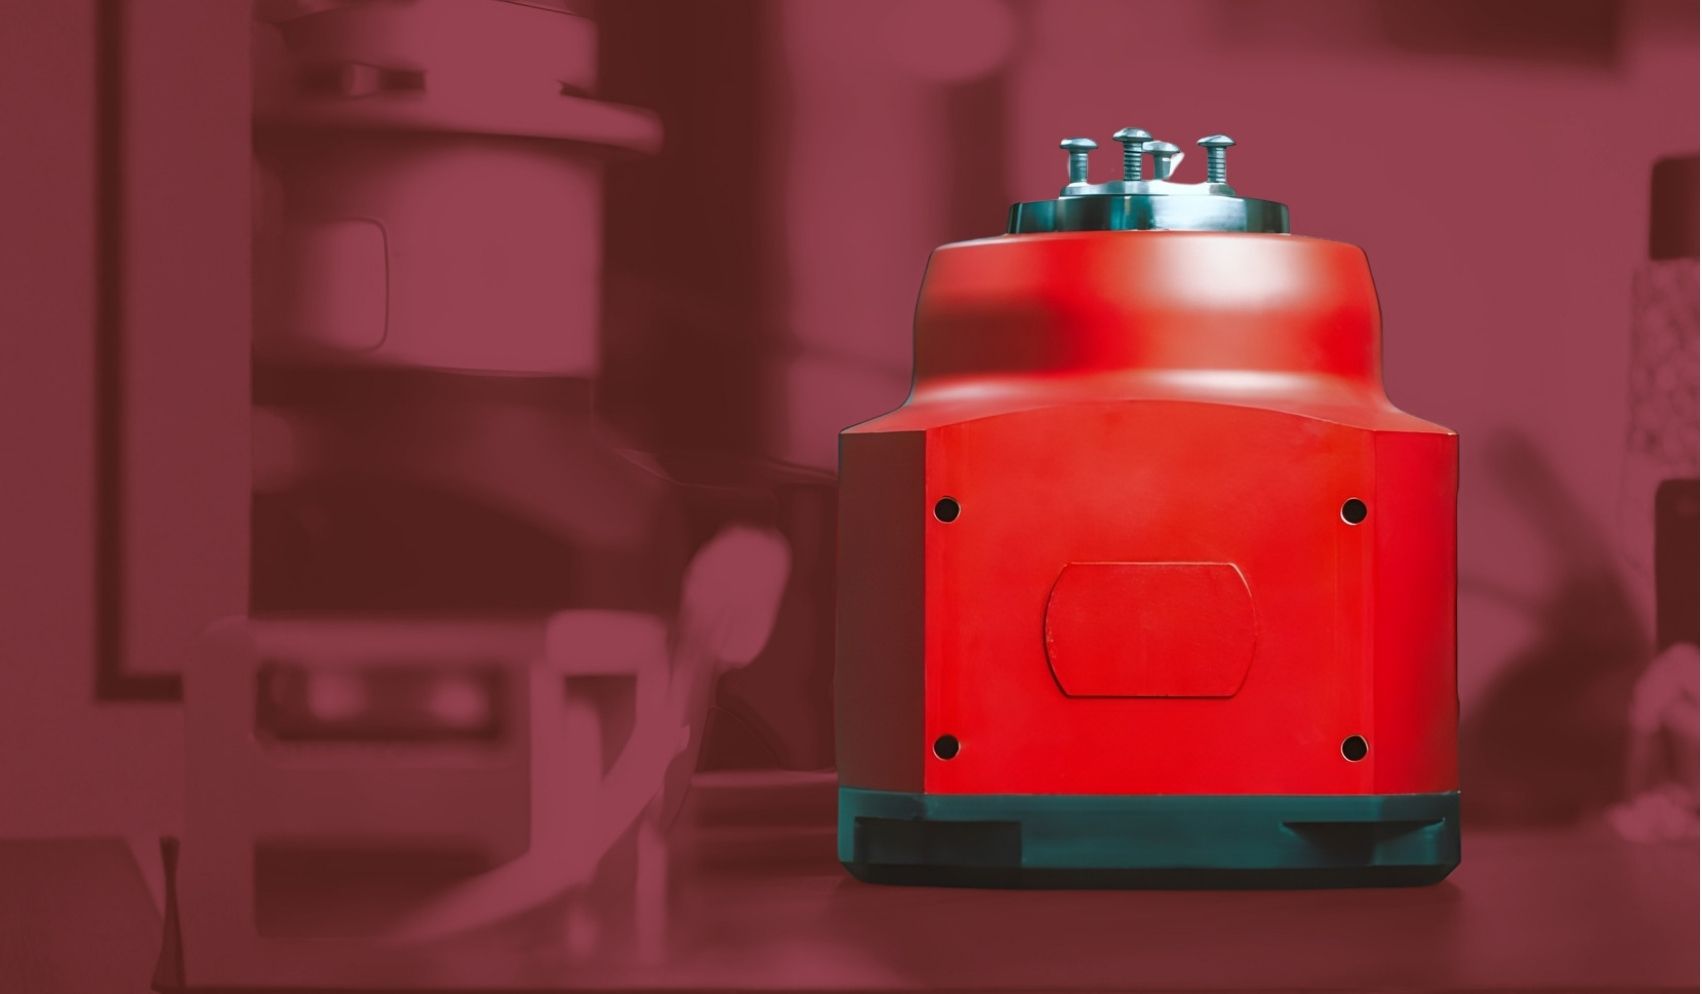
A modular technology system powered by AI algorithms for the autonomy of mobile devices and machines. RapidBase combines localization, 3D perception, motion planning, control, fleet management, and communication functions into a coherent, parameterizable hardware and software framework for machine autonomy.

Modular system

Get to know the modules

Complete autonomy backend - deploy a single module or the full stack, depending on the project stage.

Kontroler Nawigacji
01
software
Kontroler Nawigacji
Global and local path planning, 3D obstacle avoidance, and loop trajectory guidance, typically at 20-30 Hz. Support for speeds up to 3 m/s, fast loopback, precise docking, and API integration.
See the module
Lokalizacja
02
software
Lokalizacja
Determine position and orientation indoors and outdoors with <3 cm accuracy. Supports GPS, RTK, UWB, LiDAR, IMU, and computer vision with data fusion, as well as support for AMCL (Adaptive Monte Carlo Localization) and SLAM (Simultaneous Localization and Mapping).
See the module
Zarządzanie i Interfejs
03
software
Zarządzanie i Interfejs
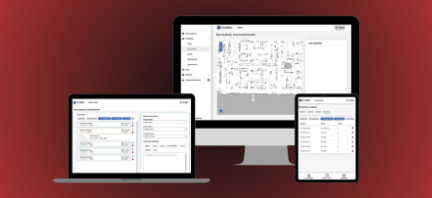
An intuitive tool for managing your entire fleet. Real-time monitoring, diagnostics, and configuration of routes, destinations, and zones for a single robot or fleet, user role management, robot management, and API integration.
See the module
Sterownik Niskopoziomowy
04
hardware
Sterownik Niskopoziomowy
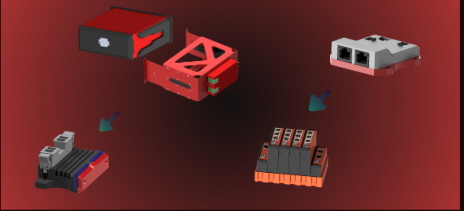
Integration of drives, sensors, and diagnostics, and communication via EtherCAT, CAN, and Ethernet, with optional Wi-Fi, LTE, and 5G connectivity. Support for safety systems (functional safety) and consistent telemetry simplify integration and service across a variety of robot configurations.
See the module
Zasilanie
05
hardware
Zasilanie
Support for 10-60V range, series and parallel battery configurations, and multi-battery architectures, including MultiBat compatibility. Stable operation is ensured by DC/DC voltage converters, a BMS (Battery Management System), and DPPM (Dynamic Power Path).
See the module
Percepcja
06
software
Perception
Przetwarzanie danych LiDAR, kamer i radarów w celu zbudowania trójwymiarowego (360°) modelu środowiska i wykrywania przeszkód w celu zapewnienia nawigacji i bezpieczeństwa. Proces obejmuje łączenie czujników, segmentację, mapę kosztów i bańkę bezpieczeństwa, zazwyczaj w zakresie 7–13 Hz, w zależności od konfiguracji.
See the module
Kinematyka adaptacyjna
07
hardware
Adaptive Kinematics
Zunifikowane sterowanie ruchem dla różnych platform. Ten kontroler obsługuje sześć typów kinematycznych oraz silniki BLDC, DC i AC z komunikacją EtherCAT, CAN lub Ethernet. Wykorzystuje rozwiązania Roboteq i FOC oraz umożliwia parametryzację działania platformy bez zmiany logiki wyższego poziomu.
See the module
Kontroler Nawigacji
01
software
Kontroler Nawigacji
Global and local path planning, 3D obstacle avoidance, and loop trajectory guidance, typically at 20-30 Hz. Support for speeds up to 3 m/s, fast loopback, precise docking, and API integration.
See the module
Lokalizacja
02
software
Lokalizacja
Determine position and orientation indoors and outdoors with <3 cm accuracy. Supports GPS, RTK, UWB, LiDAR, IMU, and computer vision with data fusion, as well as support for AMCL (Adaptive Monte Carlo Localization) and SLAM (Simultaneous Localization and Mapping).
See the module
Zarządzanie i Interfejs
03
software
Zarządzanie i Interfejs
An intuitive tool for managing your entire fleet. Real-time monitoring, diagnostics, and configuration of routes, destinations, and zones for a single robot or fleet, user role management, robot management, and API integration.
See the module
Sterownik Niskopoziomowy
04
hardware
Sterownik Niskopoziomowy
Integration of drives, sensors, and diagnostics, and communication via EtherCAT, CAN, and Ethernet, with optional Wi-Fi, LTE, and 5G connectivity. Support for safety systems (functional safety) and consistent telemetry simplify integration and service across a variety of robot configurations.
See the module
Zasilanie
05
hardware
Zasilanie
Support for 10-60V range, series and parallel battery configurations, and multi-battery architectures, including MultiBat compatibility. Stable operation is ensured by DC/DC voltage converters, a BMS (Battery Management System), and DPPM (Dynamic Power Path).
See the module
Percepcja
06
software
Perception
Przetwarzanie danych LiDAR, kamer i radarów w celu zbudowania trójwymiarowego (360°) modelu środowiska i wykrywania przeszkód w celu zapewnienia nawigacji i bezpieczeństwa. Proces obejmuje łączenie czujników, segmentację, mapę kosztów i bańkę bezpieczeństwa, zazwyczaj w zakresie 7–13 Hz, w zależności od konfiguracji.
See the module
Kinematyka adaptacyjna
07
hardware
Adaptive Kinematics
Zunifikowane sterowanie ruchem dla różnych platform. Ten kontroler obsługuje sześć typów kinematycznych oraz silniki BLDC, DC i AC z komunikacją EtherCAT, CAN lub Ethernet. Wykorzystuje rozwiązania Roboteq i FOC oraz umożliwia parametryzację działania platformy bez zmiany logiki wyższego poziomu.
See the module
Drag or use arrows
Industry standard

Proven solutions, global producers

RapidBase in action

See how it works
RapidBase

0:00 / 0:00
HetBot Group
Contact

Do you want to
start the project
right away?

Describe your machine or project. Our team will respond within 24 hours with a specific action plan tailored to your situation.

Headquarters
Stefanowskiego 18 St.
90-537 Lodz, Poland
We usually answer
within 24 hours